Sibeen Kim

Sibeen Kim

I am a second-year M.S./Ph.D. student in AI at KAIST, where I am advised by Prof. Jaegul Choo at Data and Visual Analytics Lab (DAVIAN). I received my B.S. in Biomedical Engineering from Korea University in Feb 2025.

Research Goal

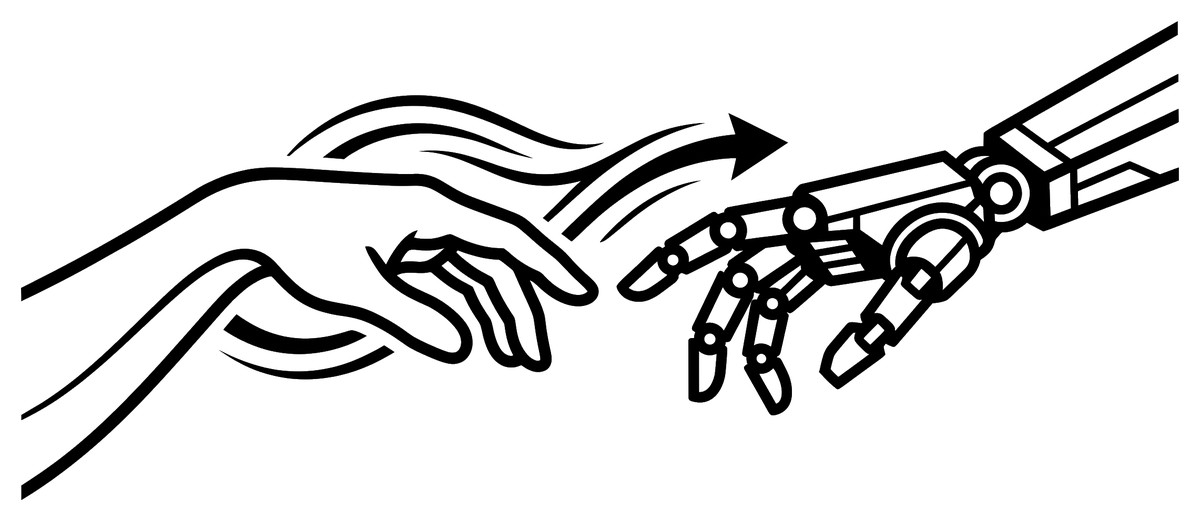
A human hand passing motion to a robot hand

I want robots that perform physical tasks humans do. My research transfers human prior into data that robots can learn from. Previously, I converted human motion, from motion capture to in-the-wild videos, into robot data. Currently, I am using agents that possess human prior to generate robot data.

Ongoing Project

Ongoing Oct 2026 -

Agentic Skill Composition for Functional Tasks in Dexterous Manipulation

Sibeen Kim, Jaegul Choo, Minho Park

TL;DR: We use agents with human prior to generate robot data for compositional, functional manipulation tasks.

*AI-generated concept video
Ongoing Oct 2026 -

Agentic Motion Generation for Variational Automation in Dexterous Manipulation

Sibeen Kim*, Kyungmin Lee*, Dongyoon Hwang*, Jaegul Choo, Hojoon Lee

TL;DR: We use agents with human prior to generate robot data for varying instances of a manipulation task.

Publications